Bullet Real-Time Physics Simulation

Bullet Real-Time Physics Simulation

Search
Skip to content
  • Blog
  • Forum
  • Github
  • PyBullet Quickstart Guide
  • Download
  • Documentation
  • Forum

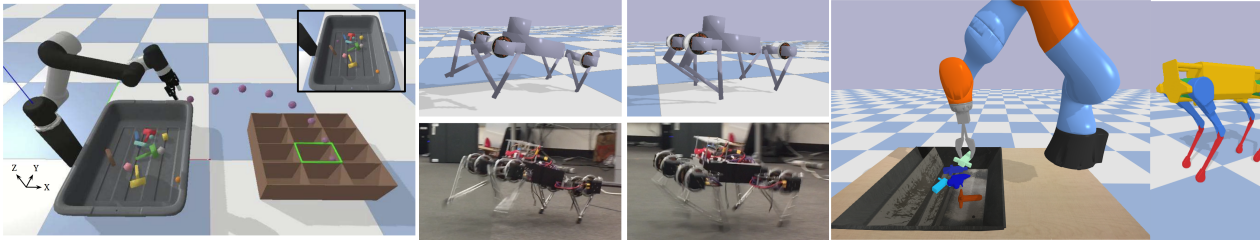
Rapidly Adaptable Legged Robots via Evolutionary Meta-Learning

March 17, 2020 admin

Robots can use meta-learning to quickly adapt from simulation to various real world conditions.

See paper at https://arxiv.org/abs/2003.01239
Post navigation

Previous PostLumote game using BulletNext PostLearning Agile Robotic Locomotion Skills by Imitating Animals

Home of Bullet and PyBullet: physics simulation for games, visual effects, robotics and reinforcement learning.

Recent Posts

  • Kubric: a scalable dataset generator
  • NeuralSim: Augmenting Differentiable Simulators with Neural Networks
  • PyBullet in a colab
  • Learning Agile Robotic Locomotion Skills by Imitating Animals
  • Assistive gym @ ICRA, 2020

Selected Video


(title expands video)

Proudly powered by WordPress