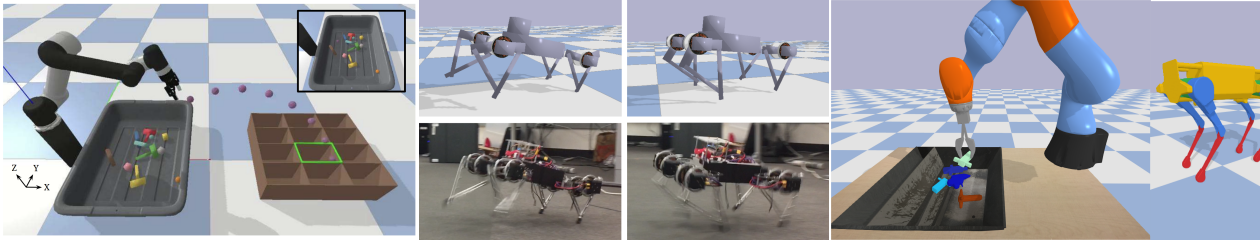
Currently, there's no verification of whether or not Bullet can support hydraulic robot simulation.
Is this a limitation for Bullet?
Is anyone able to provide a tiny example of how it might be done?
If anyone has been successful, please tell me about it!
SamQ