<?xml version="1.0" encoding="UTF-8"?>
<feed xmlns="http://www.w3.org/2005/Atom" xml:lang="en-gb">
	<link rel="self" type="application/atom+xml" href="https://pybullet.org/Bullet/phpBB3/app.php/feed/topic/13106" />

	<title>Real-Time Physics Simulation Forum</title>
	
	<link href="https://pybullet.org/Bullet/phpBB3/index.php" />
	<updated>2020-11-14T06:22:06+00:00</updated>

	<author><name><![CDATA[Real-Time Physics Simulation Forum]]></name></author>
	<id>https://pybullet.org/Bullet/phpBB3/app.php/feed/topic/13106</id>

		<entry>
		<author><name><![CDATA[Winson]]></name></author>
		<updated>2020-11-14T06:22:06+00:00</updated>

		<published>2020-11-14T06:22:06+00:00</published>
		<id>https://pybullet.org/Bullet/phpBB3/viewtopic.php?p=43188#p43188</id>
		<link href="https://pybullet.org/Bullet/phpBB3/viewtopic.php?p=43188#p43188"/>
		<title type="html"><![CDATA[Re: The contact points have been not removed cleanly when two objects are separated!]]></title>

		
		<content type="html" xml:base="https://pybullet.org/Bullet/phpBB3/viewtopic.php?p=43188#p43188"><![CDATA[
<a href="https://github.com/bulletphysics/bullet3/issues/3146" class="postlink">https://github.com/bulletphysics/bullet3/issues/3146</a><p>Statistics: Posted by <a href="https://pybullet.org/Bullet/phpBB3/memberlist.php?mode=viewprofile&amp;u=13586">Winson</a> — Sat Nov 14, 2020 6:22 am</p><hr />
]]></content>
	</entry>
		<entry>
		<author><name><![CDATA[Winson]]></name></author>
		<updated>2020-11-12T13:32:21+00:00</updated>

		<published>2020-11-12T13:32:21+00:00</published>
		<id>https://pybullet.org/Bullet/phpBB3/viewtopic.php?p=43184#p43184</id>
		<link href="https://pybullet.org/Bullet/phpBB3/viewtopic.php?p=43184#p43184"/>
		<title type="html"><![CDATA[The contact points have been not removed cleanly when two objects are separated!]]></title>

		
		<content type="html" xml:base="https://pybullet.org/Bullet/phpBB3/viewtopic.php?p=43184#p43184"><![CDATA[
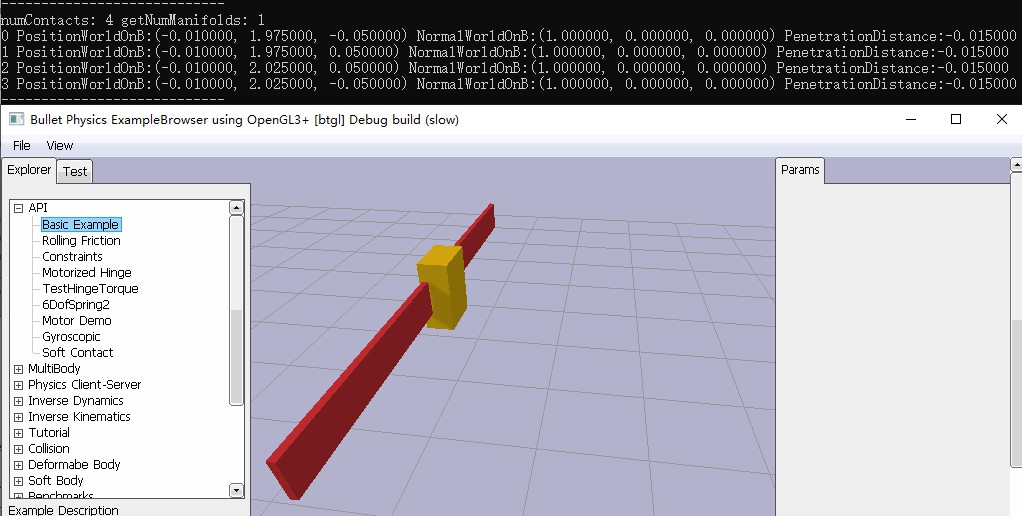
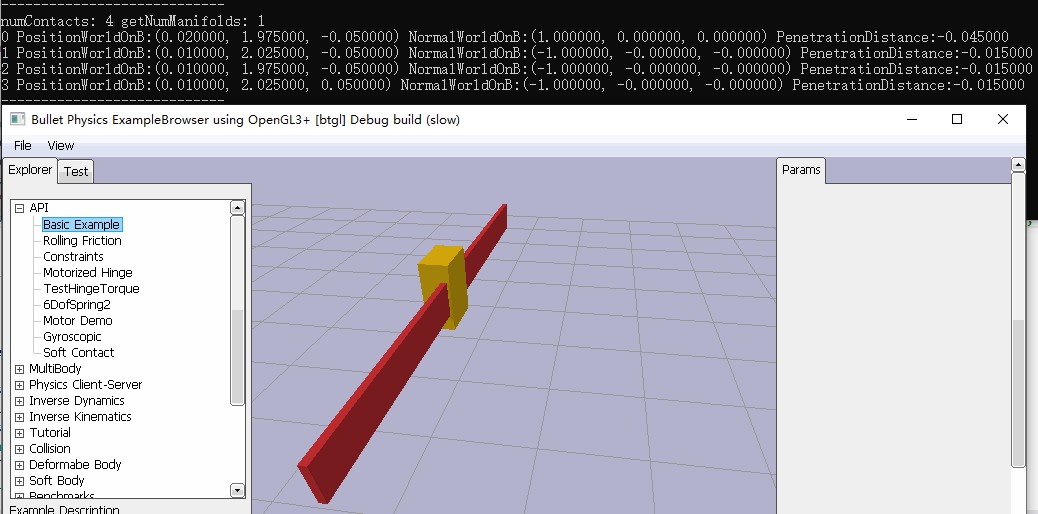
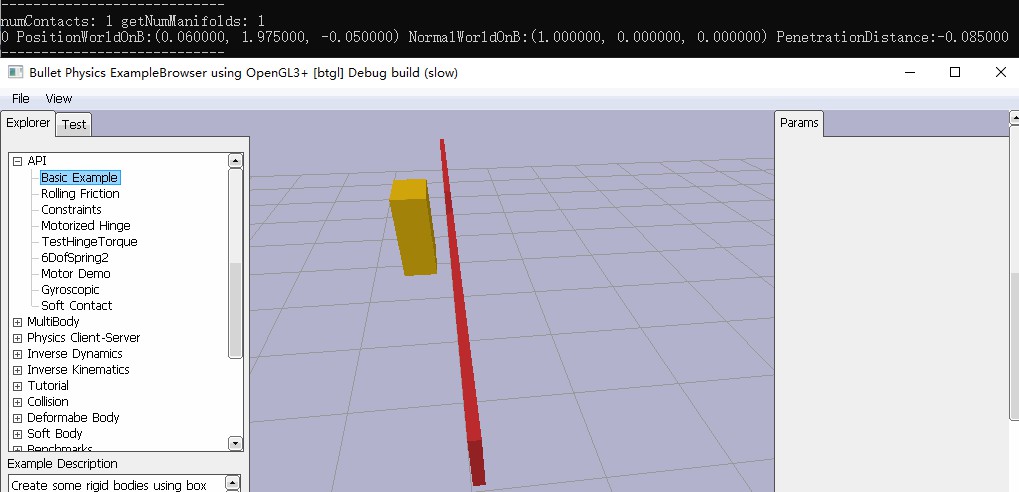
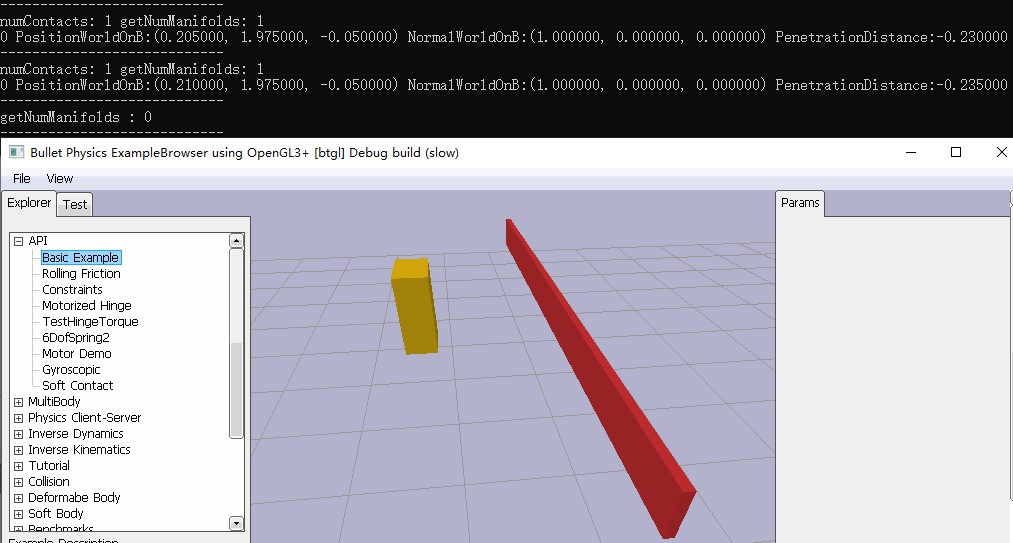
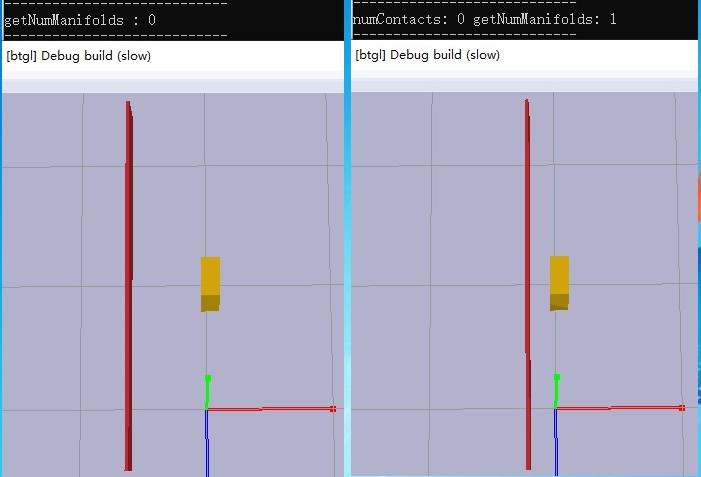
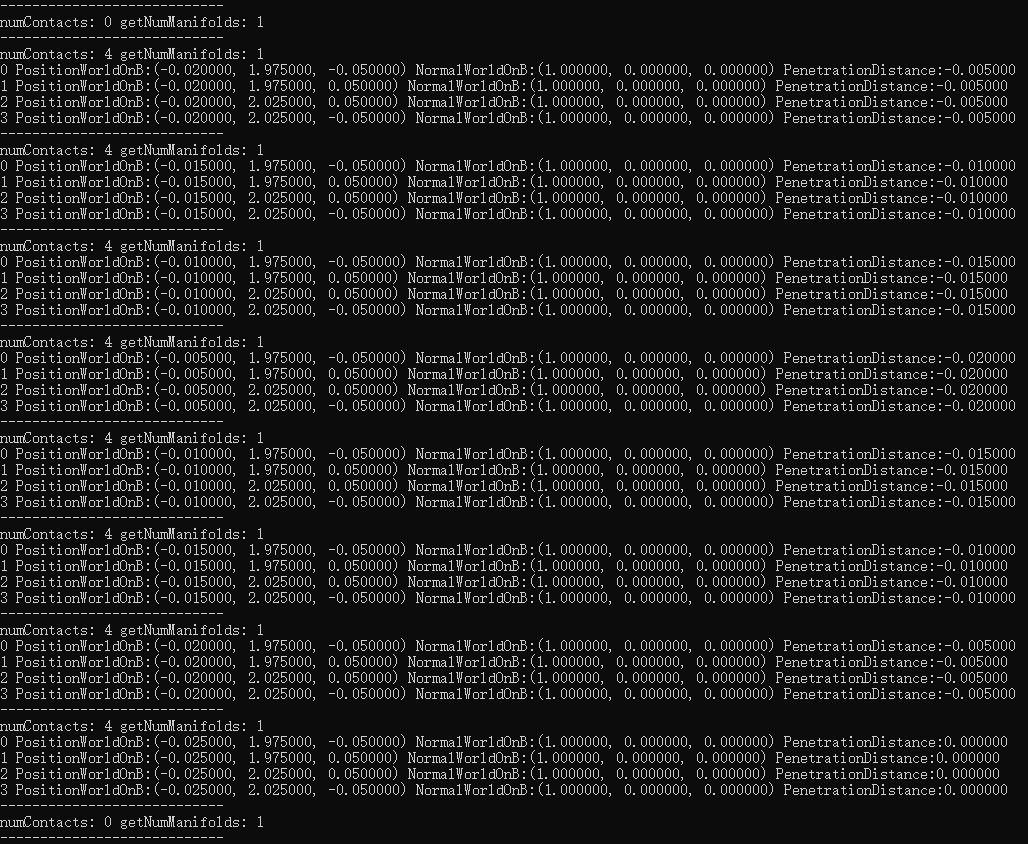
Hello everyone,<br><br>I create a btPairCachingGhostObject object as sensor and a btRigidBody object. <br>Then, I control the rigid body to move  along X-axis (move 0.005m each time) until colliding with sensor. <br><br>A illogical issue has been found: <br>When the rigid body passes through the sensor from left to right, the contact points have been not removed cleanly! <br>The following are the moving process of rigid body: <br><img src="https://i.loli.net/2020/11/12/LqWUDvj3J1Vat96.jpg" class="postimage" alt="Image"><br><br><img src="https://i.loli.net/2020/11/12/Xn2I8cu4mVRUANh.jpg" class="postimage" alt="Image"><br><br><img src="https://i.loli.net/2020/11/12/H1zucA6CxF3ZqOy.jpg" class="postimage" alt="Image"><br><br><img src="https://i.loli.net/2020/11/12/wyFlB4hbxKL3AM2.jpg" class="postimage" alt="Image"><br><br><img src="https://i.loli.net/2020/11/12/XOeu4WbmMZcNalV.jpg" class="postimage" alt="Image"><br><br><br>By the way, rigid body enters the sensor from the left side and collides with it.Rigid body doesn't go over the sensor center and then move out from the left. <br>This situation is logical that all of the contact points have been removed cleanly! <br>The following is the record of this situation: <br><img src="https://i.loli.net/2020/11/12/W7VwcnITudBxPHq.jpg" class="postimage" alt="Image"><br><br><br>Is it something wrong with Bullet collision detection algorithm?<br>I think this issue is casued by btBoxBoxCollisionAlgorithm doesn't compute correct contact point loction and normal vector.<br><br><br>Thanks help.<br><br>Here is my test code<dl class="file"><dt><span class="imageset icon_topic_attach"></span> <a class="postlink" href="https://pybullet.org/Bullet/phpBB3/download/file.php?id=1846">BasicExample.cpp</a></dt></dl><p>Statistics: Posted by <a href="https://pybullet.org/Bullet/phpBB3/memberlist.php?mode=viewprofile&amp;u=13586">Winson</a> — Thu Nov 12, 2020 1:32 pm</p><hr />
]]></content>
	</entry>
	</feed>